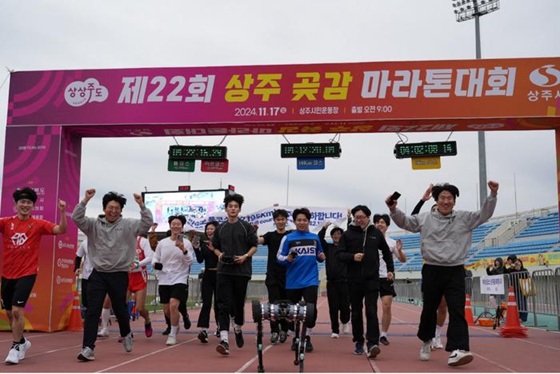
Researchers at the Korea Advanced Institute of Science and Technology have developed a quadruped robot capable of completing a 42.195-kilometer marathon on a single battery, with the work published in the journal Nature. RAIBO2, developed by a team led by Professor Jemin Hwangbo of KAIST’s Department of Mechanical Engineering, completed the Sangju Dried Persimmon Marathon in November 2024 in 4 hours, 19 minutes and 52 seconds. The robot finished the full course without charging or replacing its battery.
The researchers used the marathon to test an approach to extending robot operating range through the combined design of mechanical, electrical, actuation and control systems. Rather than focusing on individual components such as batteries or motors, the team treated energy efficiency as a system-level engineering problem.
Quadruped robots consume energy through actuators, electrical systems and mechanical components as their legs repeatedly move. The researchers analyzed energy losses across RAIBO2 and designed its systems together to reduce consumption while maintaining locomotion performance.
During the marathon, the team collected data on the robot’s internal voltage, current, temperature and battery condition. These measurements were synchronized with GPS data covering position, speed and altitude, providing more than four hours of information about the robot’s operation outside a laboratory environment.
RAIBO2 was registered as a participant in the marathon, allowing official split times to be recorded. Researchers accompanied the robot and filmed its run from the start to the finish.
The project is intended to establish design principles for robots that need to operate for extended periods in industrial settings, where energy efficiency must be considered alongside thermal management, battery performance and actuator reliability.
The researchers are now working with Raion Robotics, a KAIST faculty startup originating from Hwangbo’s laboratory, to apply the technology to commercially produced quadruped robots. The company is developing manufacturing and mass-production methods intended to reproduce the research prototype’s performance across multiple units.
Commercial versions would also need to meet requirements including water and dust resistance, operation over a range of temperatures, resistance to shock and vibration, and electromagnetic interference and compatibility standards. The development work covers mechanical and electrical systems, software, artificial intelligence and motor drivers.
“This study goes beyond demonstrating how far a quadruped robot can run. Using actual marathon data, we demonstrated how the entire robot must be designed to achieve both high locomotion performance and energy efficiency,” Hwangbo said. “We will connect the world-class performance achieved in the laboratory to products that anyone can use reliably in industrial environments.”
Photo: KAIST
